ENGR 120
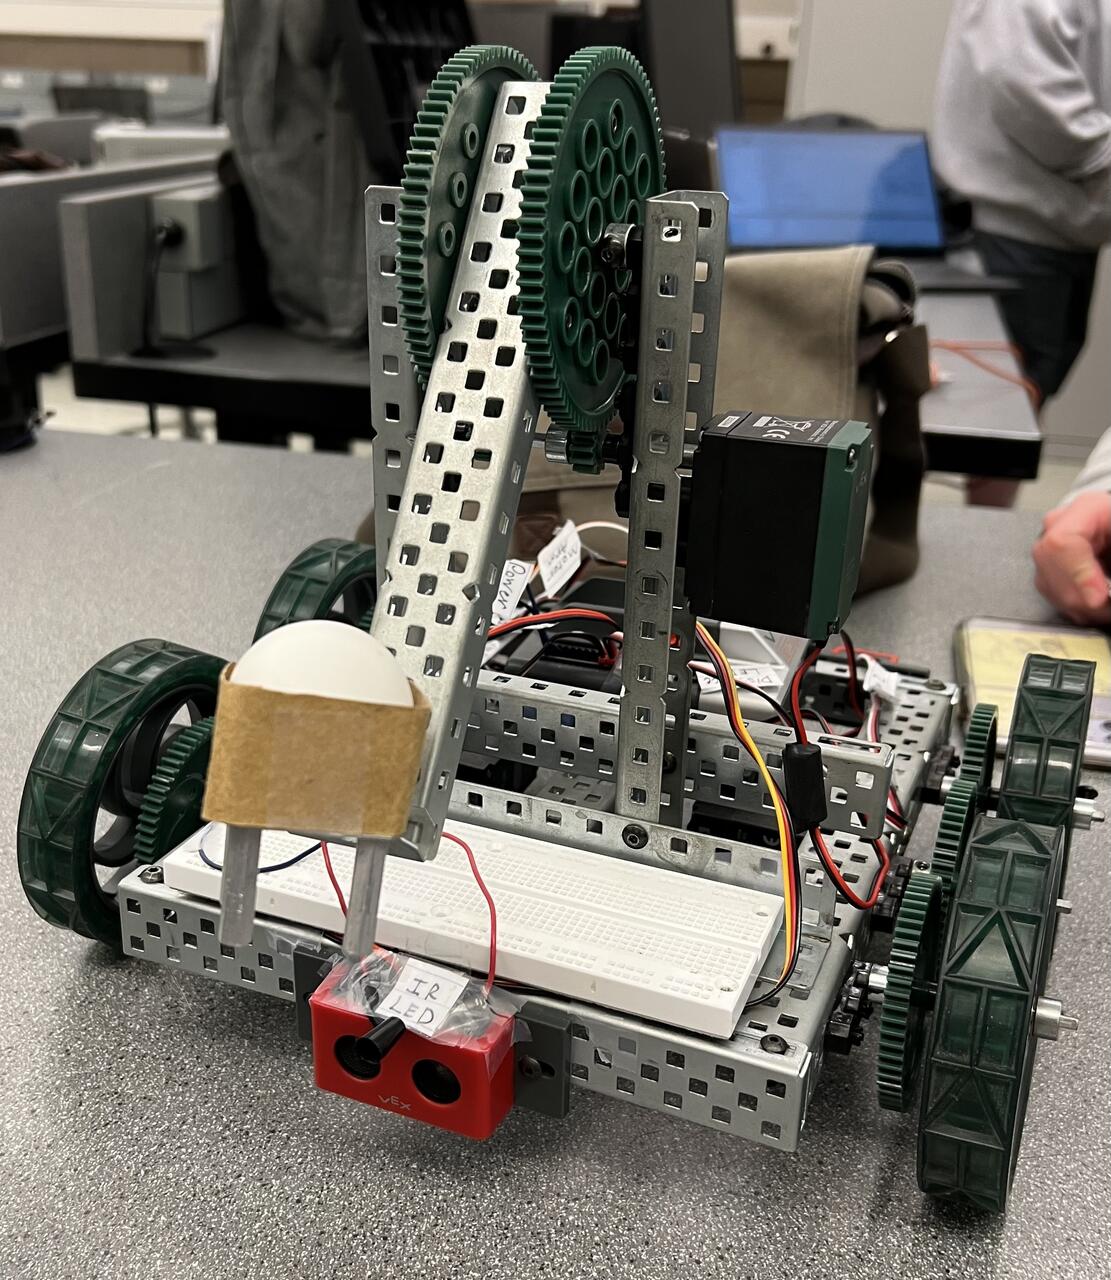
Collaborated with a team of two in building and coding an autonomous robot.
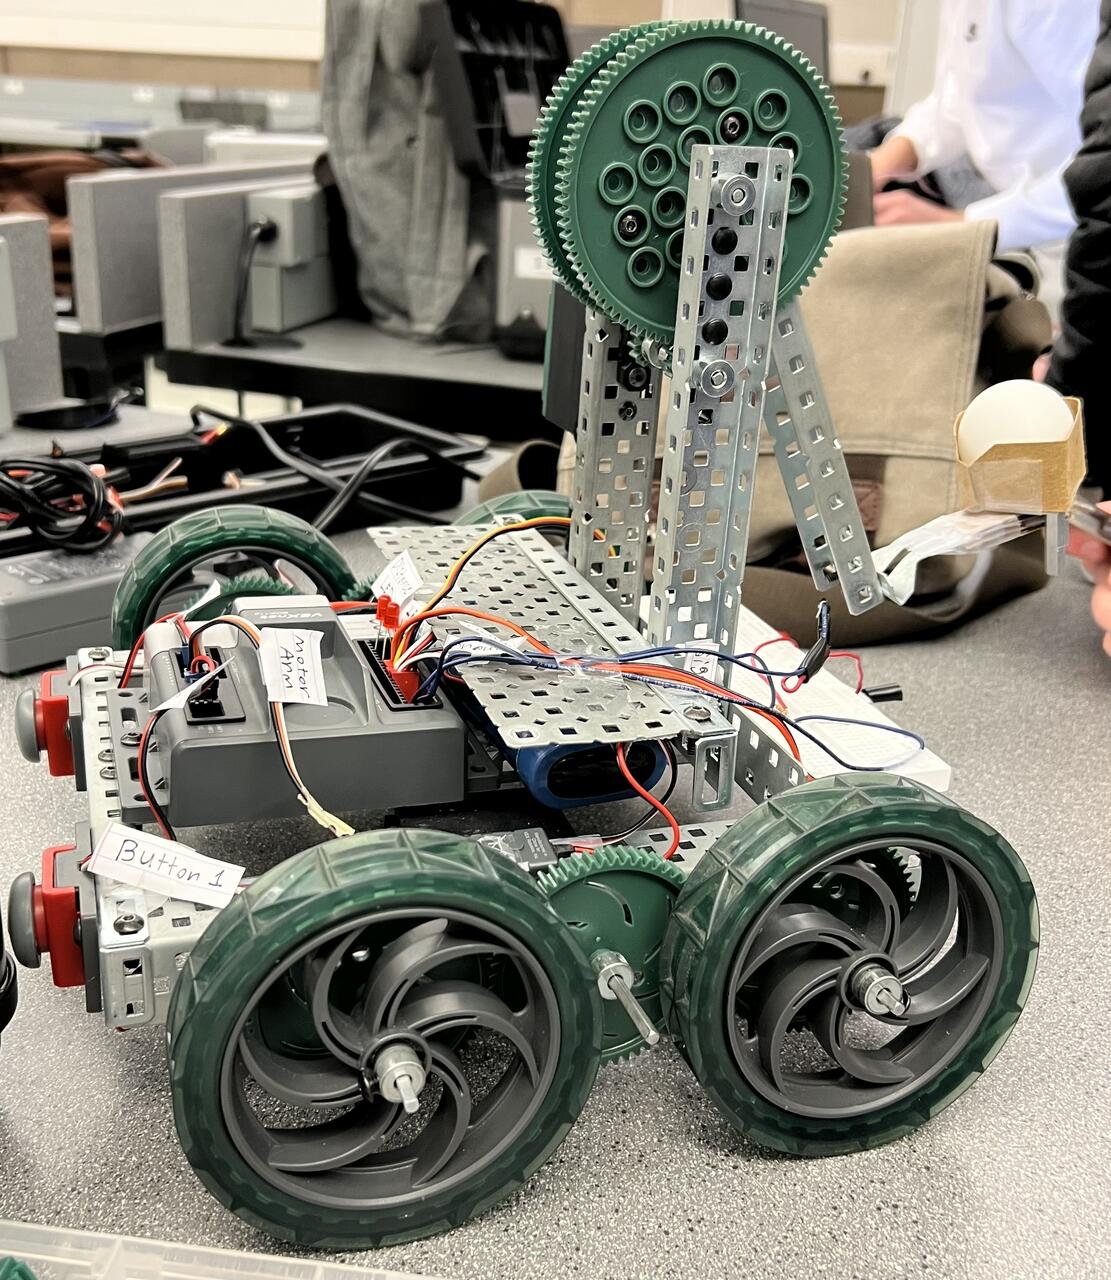
The robot was designed to locate and travel to a sensor and place a ping pong ball on top of the sensor platform. In addition to the design portion of the project, our team also collaborated on preparing an engineering recommendation report.